Ti5 Robotics T140A Humanoid Robot
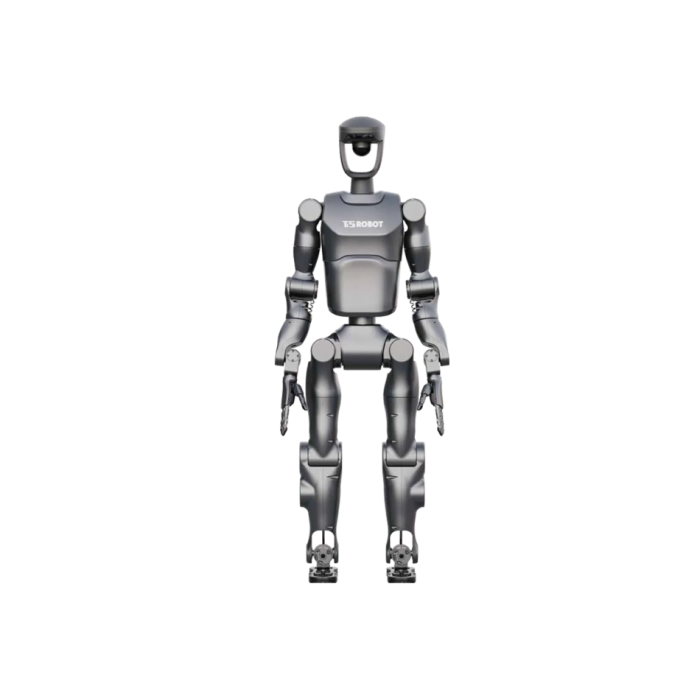
In stock
- מותג:
- TI5 ROBOTICS
- דגם:
- T140A
- ORIGIN:
- סין
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Ti5-Robotics-T140A
Ti5 Robotics T140A Humanoid Robot
The Ti5 Robotics T140A Humanoid Robot is a full-size bipedal humanoid platform standing 1.4 m tall with a gross weight of 45 kg, a 1.26 m arm span, and 42 total degrees of freedom. It is offered in two documented factory versions — a Standard model and a Flagship model — which share the same mechanical architecture, actuation, and computing hardware but differ in their onboard sensing packages. Built around harmonic-drive joint actuators, high-resolution joint encoders, and an NVIDIA Jetson AGX Orin 64 GB computing module, the T140A is aimed at developers, integrators, and research teams working on legged locomotion, dexterous manipulation, and embodied AI.
Background
Ti5 Robotics, operated by Axion Motion Technologies, specializes in the research, development, and manufacture of intelligent robotic products and in supplying specialized core components for humanoid robots. Its catalogue spans lightweight joint modules, intelligent bionic hands, collaborative robot arms, and humanoid robot actuation systems, and the T140A draws directly on that component heritage: the same class of joint-actuation technology the company supplies to OEM builders is used throughout the robot's thirty joint motors.
A component maker's approach to a complete humanoid
Because the manufacturer's core business is actuation, the T140A is best understood as a vertically integrated platform rather than an assembly of third-party drives. Every joint uses a harmonic driver type with 16/18-bit joint encoder resolution, joints communicate over CAN/EtherCAT, and the dexterous hands use a 485/CAN bus. One point of clarification: the product is presented on the vendor's website within its Humanoid Robot Actuator catalogue section. That placement reflects the site's navigation structure, not the nature of the machine — the T140A is a complete walking humanoid robot, not a standalone motor or actuator module.
Two versions, one platform
The source documentation lists a T140A Standard Model and a T140A Flagship Model. Height, weight, arm span, degrees of freedom, payload figures, joint count, travel speed, structural materials, and computing hardware are identical across both. The Flagship adds a perception stack that the Standard model does not carry: two six-dimensional force sensors at the arm end-effectors, an Intel RealSense D435i head camera, two Intel RealSense D450 wrist cameras, and obstacle-avoidance perception. Both versions are part of a single product family, and buyers select between them based on how much onboard sensing their application requires.
Technical Specifications
The following tables preserve the published configuration distinctions. Blank, malformed, or ambiguous source values are not confirmation of a capability; confirm the selected configuration during quotation.
Ti5 Robotics T140A Humanoid Robot
| Model | T140A Standard Model | T140A Flagship Model |
| Total height | 1.4m | 1.4m |
| gross weight | 45kg | 45kg |
| Arm span | 1.26m | 1.26m |
| Total number of degrees of freedom | 42 | 42 |
| Single-arm load | 3kg | 3kg |
| Number of joint motors | 30 | 30 |
| speed of travel | 1 m/s for both feet | 1 m/s for both feet |
| Hand load | 1.5KG | 1.5KG |
| End-effector repeatability | ≤0.3mm | ≤0.3mm |
| Dexterous Hand | High-precision dexterous hand (small) | High-precision dexterous hand (small) |
| Dexterous hand automation | 6 | 6 |
| End-effector sensors of both arms | / | Six-dimensional force * 2 |
| Joint driver type | harmonic | harmonic |
| Joint encoder resolution | 16/18bit | 16/18bit |
| Head visual perception | / | Intel RealSense D435i*1 |
| Wrist visual perception | / | Intel RealSense D450*2 |
| Obstacle avoidance perception | / | have |
| Control and computing power | Jeston AGX Orin 64G Developer Kit | Jeston AGX Orin 64G Developer Kit |
| Structural material | Structure: Aluminum alloy, etc. Shell: ABS, etc. | Structure: Aluminum alloy, etc. Shell: ABS, etc. |
| Communication Protocol | Joint CAN/EC, Hand 485/CAN | Joint CAN/EC, Hand 485/CAN |
How do the Standard and Flagship versions differ?
Mechanically they are the same robot. The difference is perception. The Standard model ships without end-effector force sensing, head or wrist cameras, or obstacle-avoidance perception, making it suited to teams that intend to integrate their own sensor suite or that focus on locomotion and control research where external motion capture or lab instrumentation supplies the perception layer. The Flagship model arrives sensor-equipped for vision-guided manipulation and navigation work out of the box, with dual six-axis force sensing at the wrists for contact-rich tasks. Both versions share the same Jetson AGX Orin 64 GB compute, so software developed on one generally maps to the other, subject to the available sensors.
Who is the Ti5 Robotics T140A for?
The T140A targets organizations that need a full-size, human-proportioned bipedal platform rather than a tabletop or wheeled research robot. Typical buyers include:
- University and institutional research groups studying bipedal locomotion, whole-body control, and dexterous manipulation.
- Robotics and AI developers building and testing embodied-AI software stacks on real hardware with documented joint-level interfaces.
- System integrators evaluating humanoid platforms for industrial and commercial pilot deployments.
- Education providers running advanced robotics curricula where students work with production-grade actuation, encoders, and real-time communication buses.
What is the Ti5 Robotics T140A used for?
Based on the manufacturer's stated application areas and the platform's documented capabilities, representative use cases include:
- Bipedal locomotion research — gait generation, balance control, and walking studies at a documented 1 m/s travel speed.
- Dexterous manipulation development — two 6-DOF high-precision hands with a 1.5 kg hand load and ≤0.3 mm end-effector repeatability.
- Industrial production trials — evaluating humanoid handling of light payloads up to 3 kg per arm in pilot settings.
- Scientific research and education — a standardized platform for coursework, theses, and reproducible experiments.
- Medical and rehabilitation research environments — a human-scale platform for investigation in this vendor-listed application area, within each institution's own research framework.
- Commercial-scenario prototyping — vision-guided demonstration and service tasks, particularly on the sensor-equipped Flagship version.
Pricing and Availability
The manufacturer does not publish list pricing for the T140A, and final cost depends on the version selected (Standard or Flagship) and any integration or support requirements agreed at order time. Both documented versions are quoted on request. To obtain current pricing, lead time, and configuration guidance, submit a quote request through this listing and a specialist will respond with a tailored proposal.
Frequently Asked Questions
How many degrees of freedom does the T140A have?
The platform has 42 total degrees of freedom, driven by 30 joint motors, plus two dexterous hands with 6 degrees of freedom each as documented by the manufacturer.
What computing hardware does the T140A use?
Both versions are controlled by an NVIDIA Jetson AGX Orin 64 GB Developer Kit, providing onboard compute for perception and control workloads.
Does the Standard model include cameras?
No. Head and wrist visual perception, obstacle-avoidance perception, and end-effector force sensors are documented only on the Flagship model; the Standard model omits these.
How much can the T140A carry?
The documented single-arm load is 3 kg, and the dexterous hand load is 1.5 kg, with end-effector repeatability of ≤0.3 mm on both versions.
What actuation and communication does the robot use?
All joints use harmonic drivers with 16/18-bit encoder resolution. Joints communicate over CAN/EtherCAT, and the hands use a 485/CAN bus.
Is the T140A an actuator module or a complete robot?
It is a complete 1.4 m bipedal humanoid robot. Its listing under the vendor's actuator catalogue section reflects website navigation, not the product type.
Where can I buy the Ti5 Robotics T140A and what does it cost?
The T140A can be purchased through this listing. Because pricing depends on the chosen version and configuration, cost is provided by quotation — use the quote request option on this page to receive current pricing and availability.
Summary
The Ti5 Robotics T140A is a 1.4 m, 45 kg bipedal humanoid with 42 degrees of freedom, harmonic-drive joints, and Jetson AGX Orin compute, offered as a sensor-light Standard model and a fully perception-equipped Flagship model. Built by a manufacturer whose core business is humanoid actuation, it offers research groups, developers, and integrators a documented, component-grade platform in two clearly differentiated versions. For specifications, version comparison, and a tailored quotation, this page is the starting point.